Available for Mechatronics & Embedded Roles

Sreyas
Krishna

Mechatronics engineer building embedded systems, robotics, and connected hardware — including an ESP32 DMX controller for live stage lighting.

Mechatronics & Embedded Systems

About Me

I'm a Mechatronics Engineer with hands-on expertise spanning embedded hardware, sensor-actuator interfacing, circuit-level debugging, and microcontroller programming. Comfortable owning hardware from CAD mechanics and KiCad schematics through C/C++ firmware to field-tested prototypes.

4+Working Hardware Prototypes
< 15msSensor-to-Actuator Response
100%Hands-On Breadboard & PCB Bring-Up
6-DOFIMU Tilt & Motion Tracking
Technical Capabilities & Toolchain
Microcontrollers & Platforms
ESP32 (WiFi & Bluetooth)Arduino Nano / UnoRaspberry Pi 4GPIO Interfacing
Protocols & Hardware Busses
UART (115.2k)I2C (Sensors & IMU)SPI BusPWM TimersMQTT IoTHTTP REST
Sensors, Actuators & Motor Control
MPU6050 6-Axis IMUHC-SR04 SonarNEMA 17 Stepper MotorsSG90 ServosHaptic Motors
CAD, EDA & Prototyping
KiCad PCBFusion 360SolidWorksUltimaker Cura 3DOscilloscope & Multimeter
Languages & Toolchains
Embedded CC++Python 3OpenCVLinux CLI / BashGit
Interactive Engineering Testbench

Hardware Lab

Test live sensor-actuator interlocks, inspect real-time waveforms, and execute firmware diagnostics directly in the browser.

Sonar Distance
35 cm
Motor Speed
120 RPM
Safety Interlock
CLEAR (Running)
NEMA 17 Stepper + HC-SR04 Sonar Interlock
Obstacle Proximity35 cm
Target Motor Speed120 RPM
Field-Tested Hardware & Firmware

Featured Builds

From a Wi-Fi ESP32 lighting controller and its Android app to robotics, assistive devices, and embedded prototypes.

00
Embedded Systems · Stage Lighting

Do It Control Deck — DMX Lighting Controller

ESP32 · DMX512 · Android
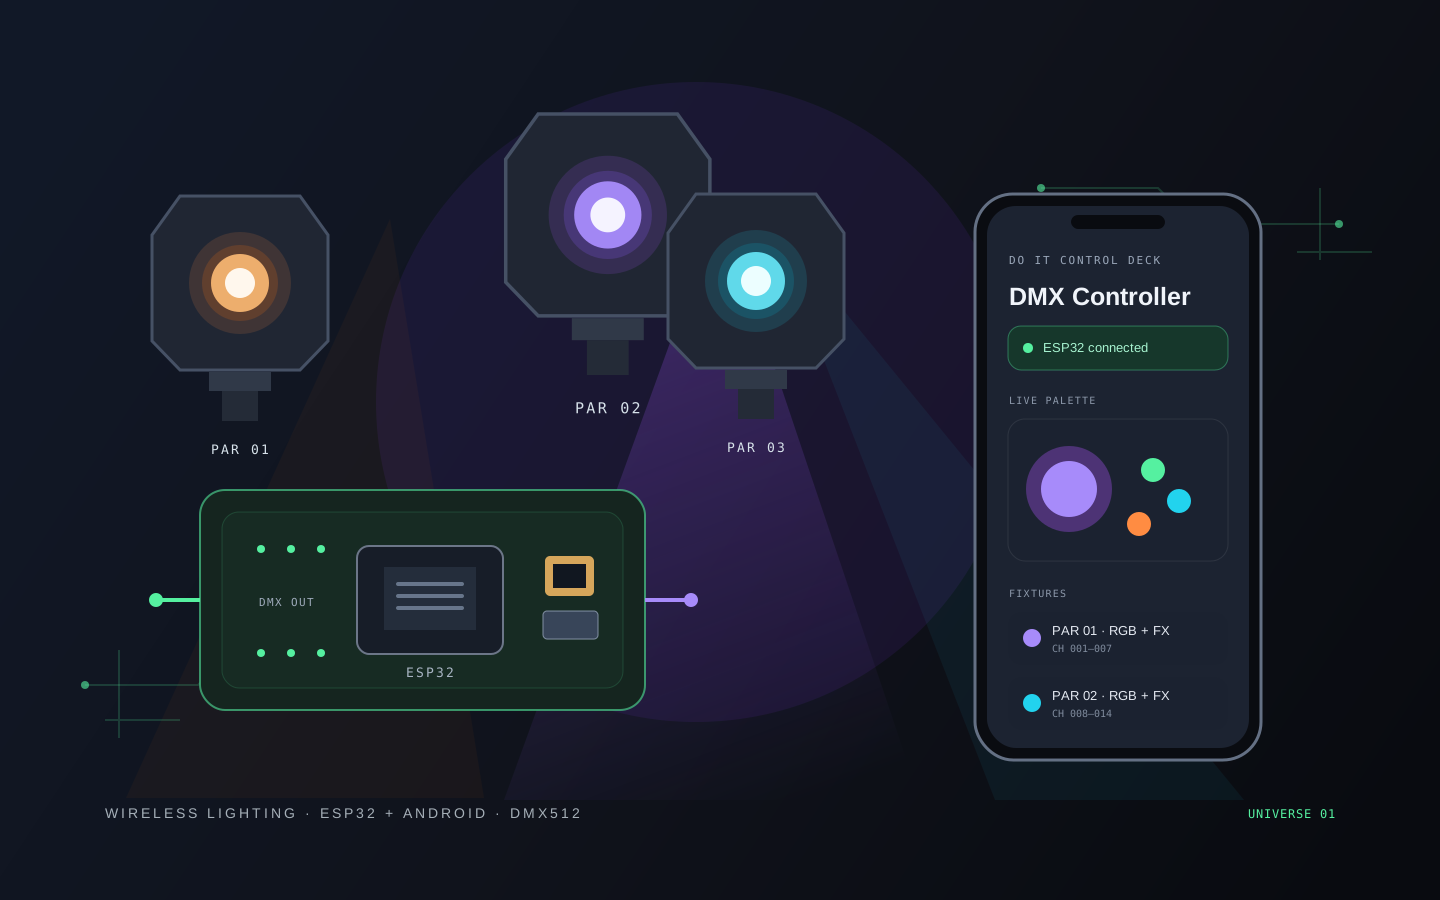
Do It Control Deck — DMX Lighting Controller project illustration
System illustration · ESP32 + Android + DMX

An ESP32 and Android control surface for DMX par lights

Built a wireless lighting controller around an ESP32 access point and an Android companion app. The app sends control packets over UDP; the ESP32 maps fixture values into a DMX universe and transmits them to par lights. The Android DMX workspace includes live palettes, fixture patching, color and effect controls, groups, saved scenes, and manual channel control.

  1. 01 / Android appSelect fixtures, colours, and saved scenes.
  2. 02 / ESP32Receive commands over Wi-Fi and UDP.
  3. 03 / DMX par lightsTranslate channel values into stage lighting.
01
IoT · Embedded Systems

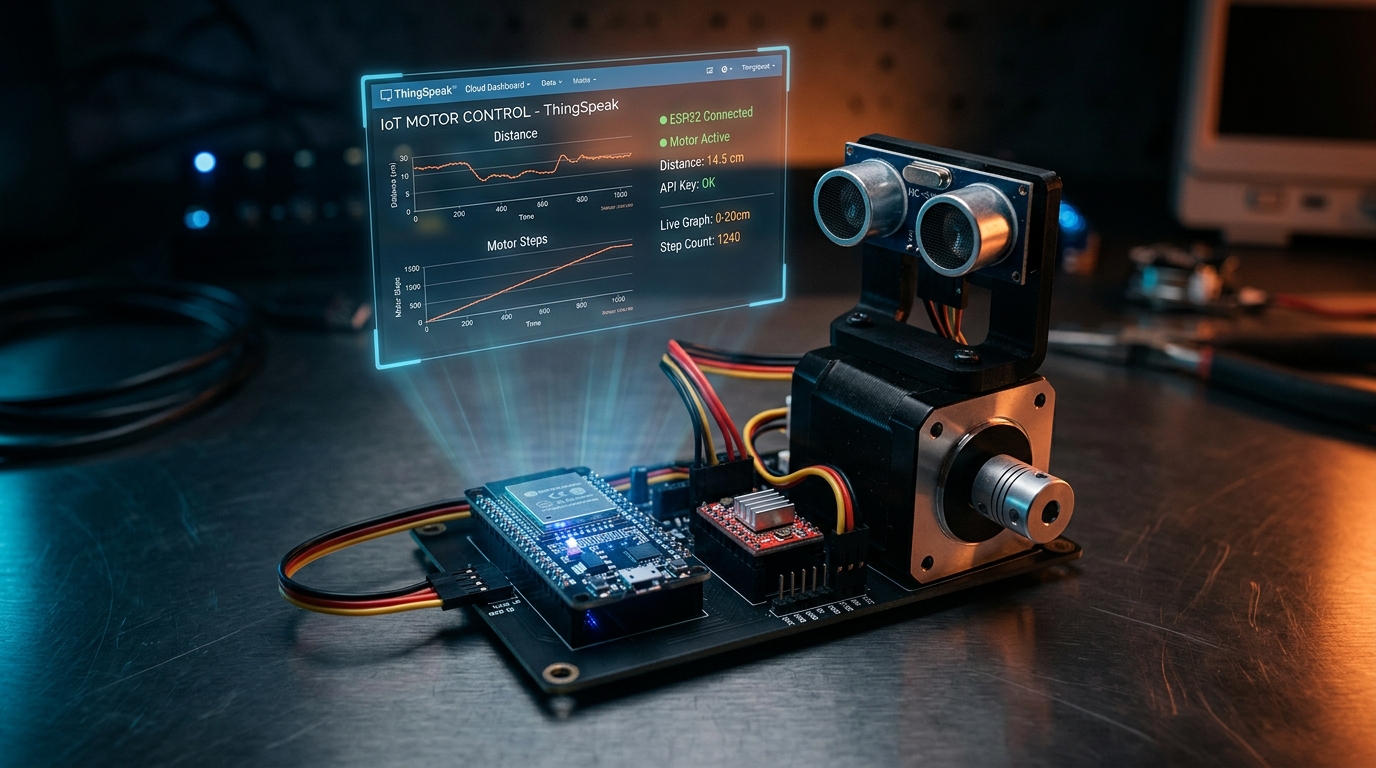
Cloud-Controlled Stepper Motor

ESP32 · ThingSpeak API · Stepper Driver
Cloud-Controlled Stepper Motor project illustration

ESP32 polling ThingSpeak TalkBack with ultrasonic obstacle emergency interlock

Engineered an IoT motor control platform enabling remote command execution over WiFi. The ESP32 constantly polls a ThingSpeak TalkBack command queue while continuously scanning an HC-SR04 ultrasonic sensor. If an obstruction is detected within 10cm, an immediate software safety shutdown halts the stepper motor driver in under 10ms.

02
Assistive Tech · Sensors & Servos

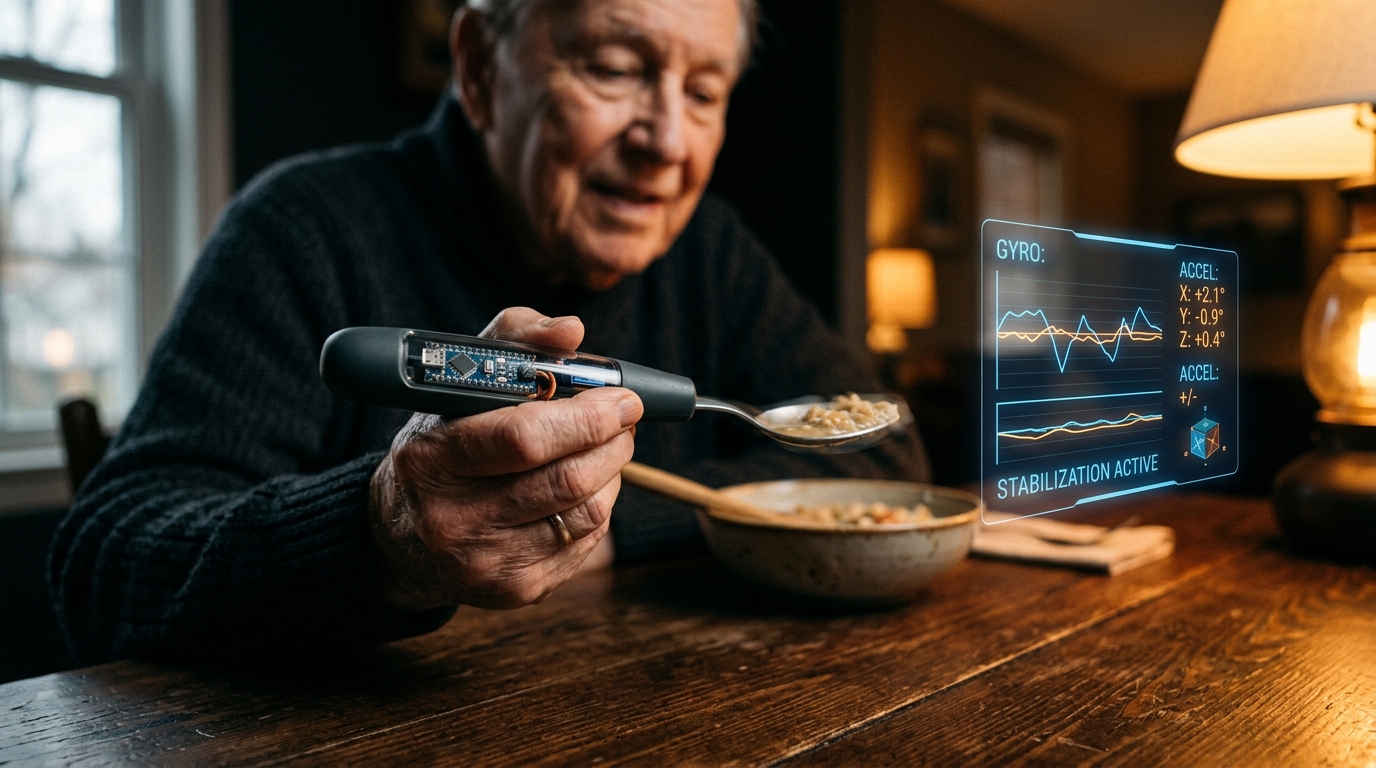
Self-Stabilizing Spoon for Parkinson’s

Arduino Nano · MPU6050 6-Axis IMU · SG90 Micro Servo
Self-Stabilizing Spoon for Parkinson’s project illustration

Active tremor compensation using MPU6050 6-DOF IMU and dynamic servo correction

Designed and assembled an ergonomic assistive spoon to counteract hand tremors in patients with Parkinson’s or essential tremor. An MPU6050 sensor reads pitch/roll angular tilt over I2C, calculates the anti-phase compensation angle, and dynamically drives an SG90 micro servo to maintain the spoon level.

03
Assistive Tech · Wearables

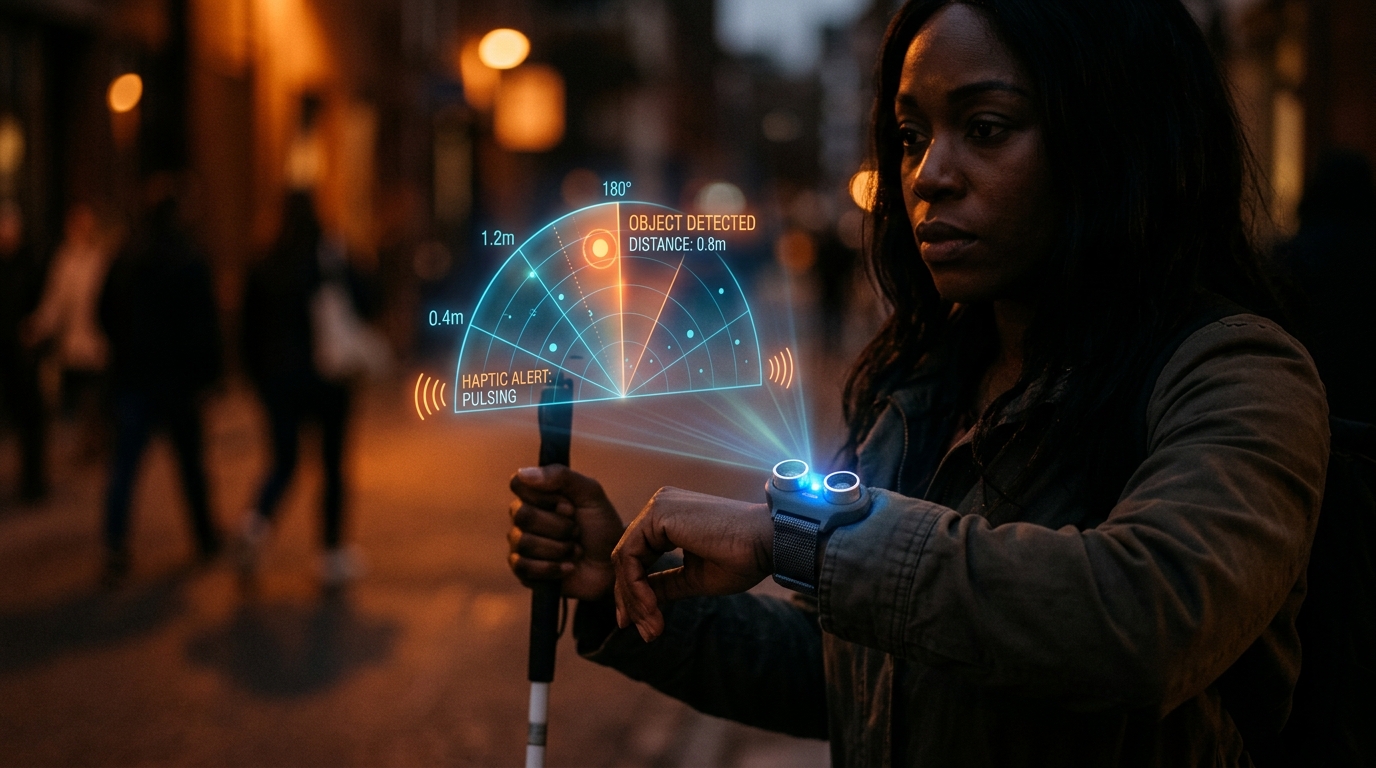
Smart Obstacle Detector

Arduino Nano · HC-SR04 Sonar · Haptic Vibration Coin
Smart Obstacle Detector project illustration

Wearable ultrasonic spatial radar with dual haptic vibromotors and audio tone alert

A compact wearable navigation aid for visually impaired users. Utilizes an HC-SR04 sonar module that dynamically adjusts vibration motor pulse frequency and buzzer pitch inversely proportional to obstacle proximity, providing intuitive spatial feedback.

04
Computer Vision · Robotics

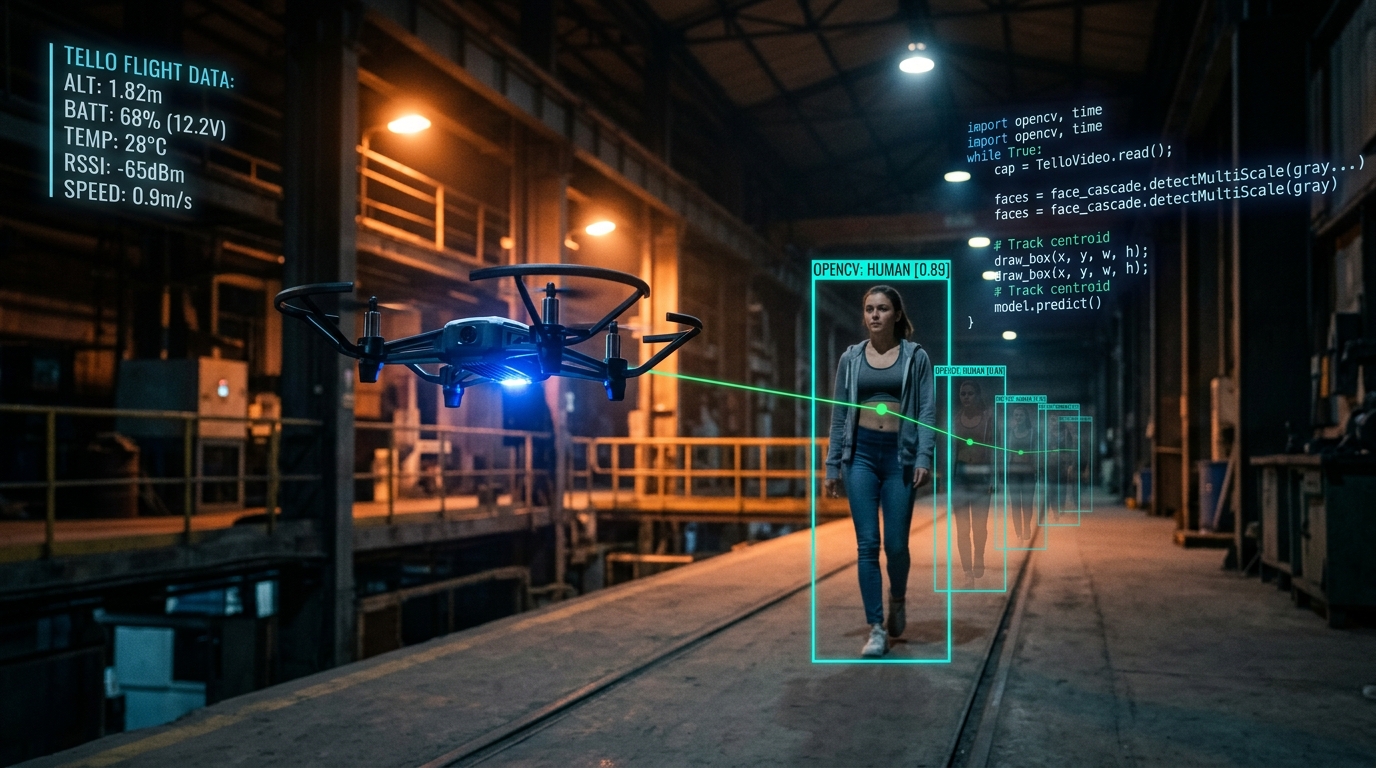
Human-Following Autonomous Drone

Python 3 · OpenCV · DJI Tello Py SDK
Human-Following Autonomous Drone project illustration

Real-time OpenCV centroid visual servoing and proportional velocity flight controller

Autonomous visual tracking system using Python, OpenCV, and the DJI Tello SDK. Captures 720p 30fps video stream over WiFi, runs color-space segmentation and pedestrian detection, and calculates offset vectors between target bounding box center and camera frame center to generate real-time yaw, pitch, and throttle command vectors.

Engineering Capabilities

What I Build

From initial concept CAD and circuit diagrams to embedded firmware and field-tested hardware.

01

Embedded Hardware & Circuit Design

Designing custom embedded systems from microcontroller selection (ESP32, Arduino) to module-level circuit design, KiCad schematics, and sensor integration.

Schematic CaptureKiCad PCB LayoutPower Rail DesignBoard Bring-Up
02

IoT & Cloud Telemetry Systems

Engineering low-latency sensor telemetry pipelines, remote data monitoring, and automated cloud queues with ThingSpeak and MQTT.

ThingSpeak TalkBackMQTT Data FeedsWiFi Sensor LoggingCloud Telemetry
03

Robotics & Motor Actuation

Building articulated robotic prototypes with precise stepper motor stepping, servo angle positioning, sensor feedback (IMU / Sonar), and computer vision tracking.

Stepper Motor DrivingServo Angle ControlIMU Motion SensingOpenCV Visual Tracking
04

Embedded C/C++ Firmware Development

Writing deterministic embedded C/C++ code for microcontroller platforms with hardware interrupts, non-blocking timing loops, and I2C, SPI, UART bus communications.

C/C++ Arduino CodeNon-blocking TimingI2C / SPI / UART BussesSensor Calibration
05

3D CAD Modeling & Prototyping

Translating functional electromechanical concepts into parametric 3D models using Fusion 360 & SolidWorks, followed by precision FDM 3D printing and assembly.

Fusion 360 Parametric CADEnclosure DesignFDM 3D Printing (Cura)Tolerance Fitting
06

Hardware Testing & Diagnostics

Comprehensive circuit troubleshooting, signal noise filtering, multimeter / oscilloscope testing, and field validation to guarantee prototype reliability.

Circuit TroubleshootingOscilloscope Waveform ChecksNoise FilteringField Testing
Collaboration & Inquiries

Get in Touch

Have an embedded hardware project, mechatronics role, or robotics collaboration in mind? Let's connect.

Send a Direct Message

Fill out the form below to initiate direct email communication with Sreyas.